US12767359 - Dynamic warhead pointing and stabilization independent from flight vector
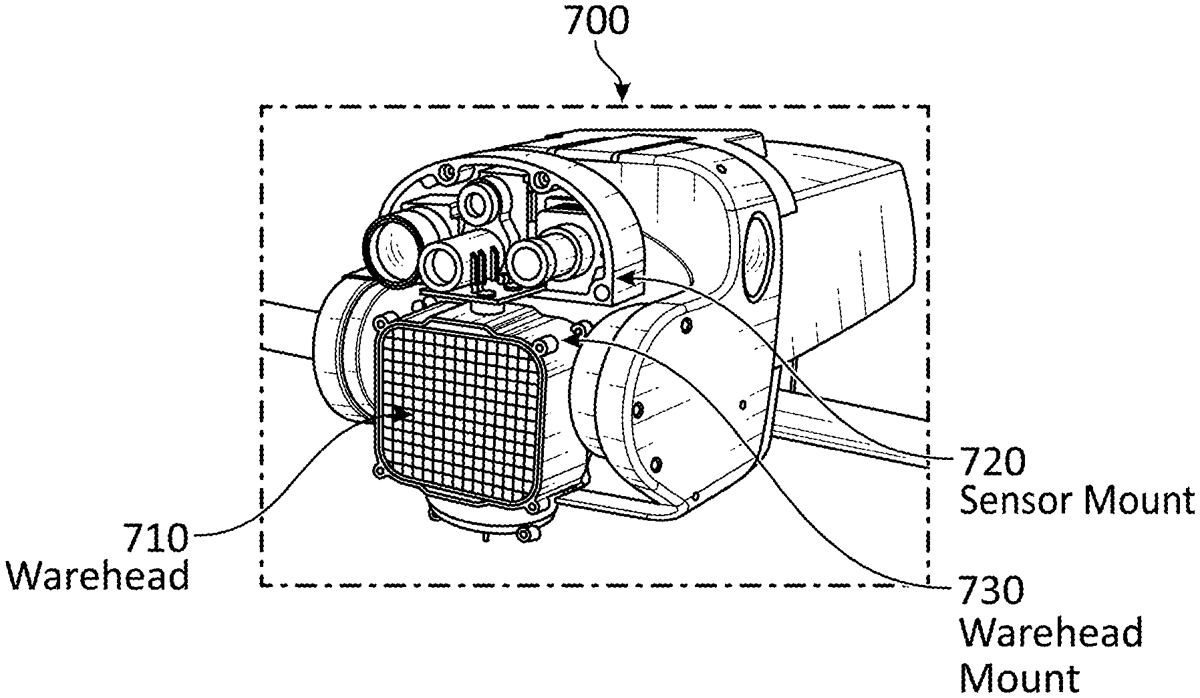
The patent describes a system for an unmanned aerial vehicle (UAV) that includes a gimbal system with targeting sensors and a warhead mount, allowing for independent warhead orientation and targeting. The logic device within the UAV tracks a target, calculates an attack vector, and determines a point of aim for the warhead, enabling precise targeting regardless of the UAV’s flight path.
Claim 1
1 . A system comprising: an unmanned aerial vehicle (UAV) comprising a body and a plurality of propulsion systems; a gimbal system comprising: a plurality of targeting sensors on a sensor mount; and a warhead mount configured to carry and deploy a warhead, wherein the gimbal system is configured to move the sensor mount and the warhead mount together; and a logic device configured to: detect a target along a UAV flight path; track the target using sensed data from the targeting sensors; calculate an attack vector for the UAV to intercept the target, the attack vector defining a direction from which the UAV is to approach the target; calculate a point of aim for the warhead, wherein the point of aim is independent of the attack vector; and instruct the gimbal system to orient the warhead and the sensor mount according to the calculated point of aim. an unmanned aerial vehicle (UAV) comprising a body and a plurality of propulsion systems; a gimbal system comprising: a plurality of targeting sensors on a sensor mount; and a warhead mount configured to carry and deploy a warhead, wherein the gimbal system is configured to move the sensor mount and the warhead mount together; and a plurality of targeting sensors on a sensor mount; and a warhead mount configured to carry and deploy a warhead, wherein the gimbal system is configured to move the sensor mount and the warhead mount together; and a logic device configured to: detect a target along a UAV flight path; track the target using sensed data from the targeting sensors; calculate an attack vector for the UAV to intercept the target, the attack vector defining a direction from which the UAV is to approach the target; calculate a point of aim for the warhead, wherein the point of aim is independent of the attack vector; and instruct the gimbal system to orient the warhead and the sensor mount according to the calculated point of aim. detect a target along a UAV flight path; track the target using sensed data from the targeting sensors; calculate an attack vector for the UAV to intercept the target, the attack vector defining a direction from which the UAV is to approach the target; calculate a point of aim for the warhead, wherein the point of aim is independent of the attack vector; and instruct the gimbal system to orient the warhead and the sensor mount according to the calculated point of aim.
Google Patents
https://patents.google.com/patent/US12767359
USPTO PDF
https://image-ppubs.uspto.gov/dirsearch-public/print/downloadPdf/12767359